Scout & recon.
Map routes, hazards and approaches to sites of interest.
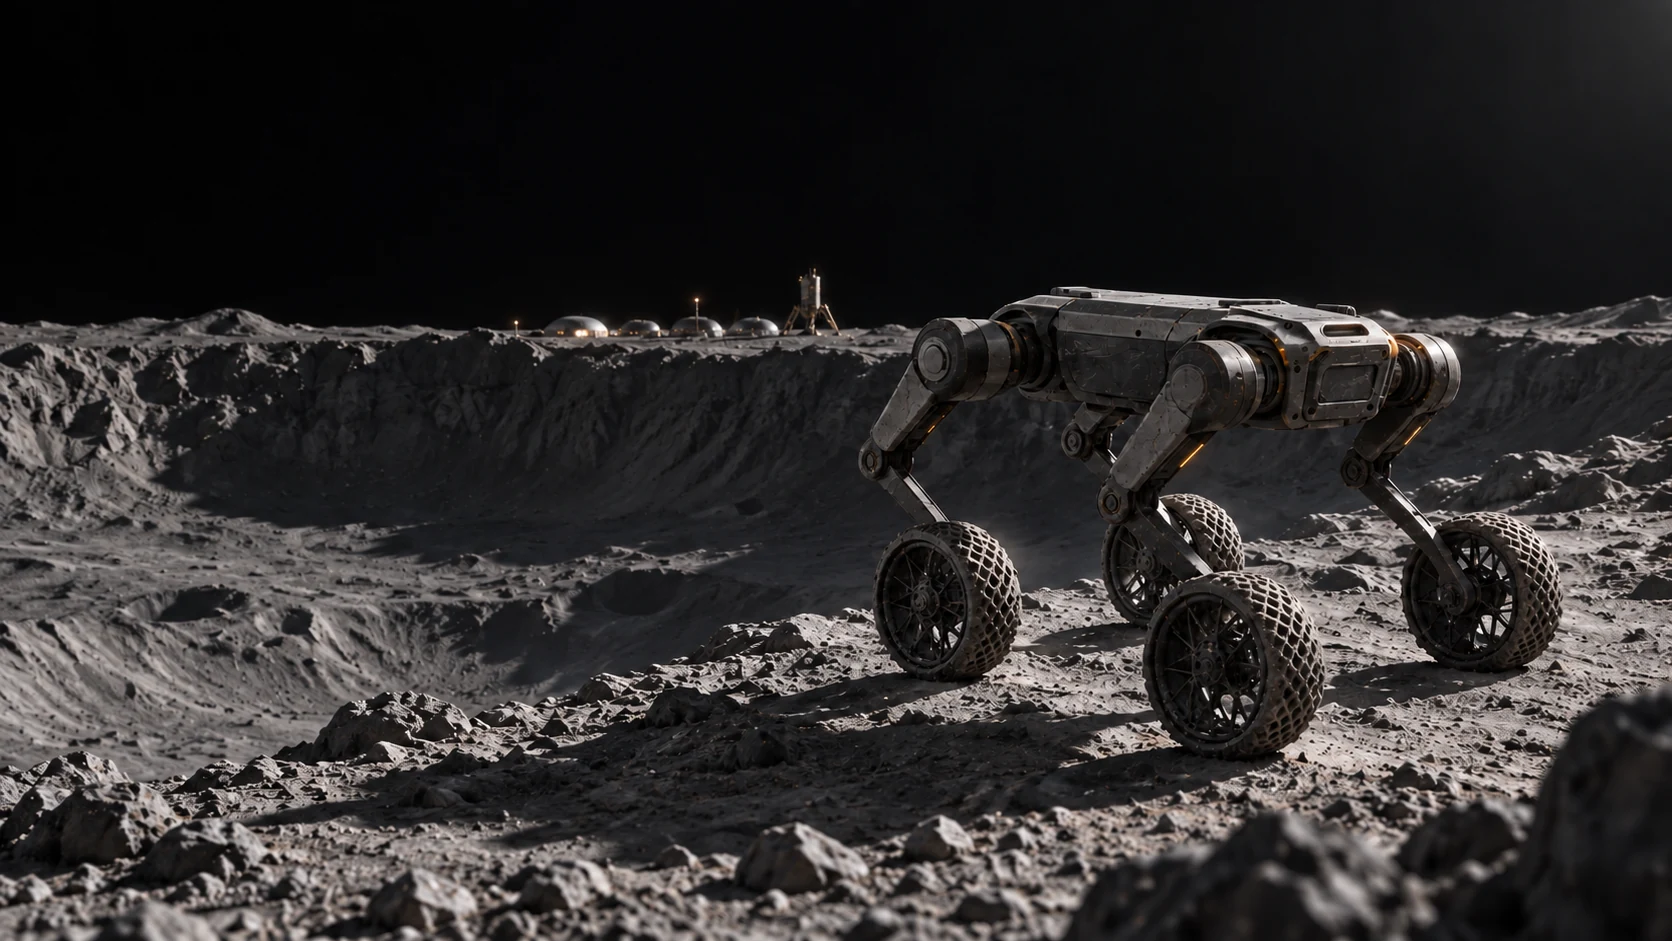
Our first robot: REXMI, a wheeled quadruped for lunar missions.Wheels for distance.
Legs for what lies ahead.
01 THE HORIZON
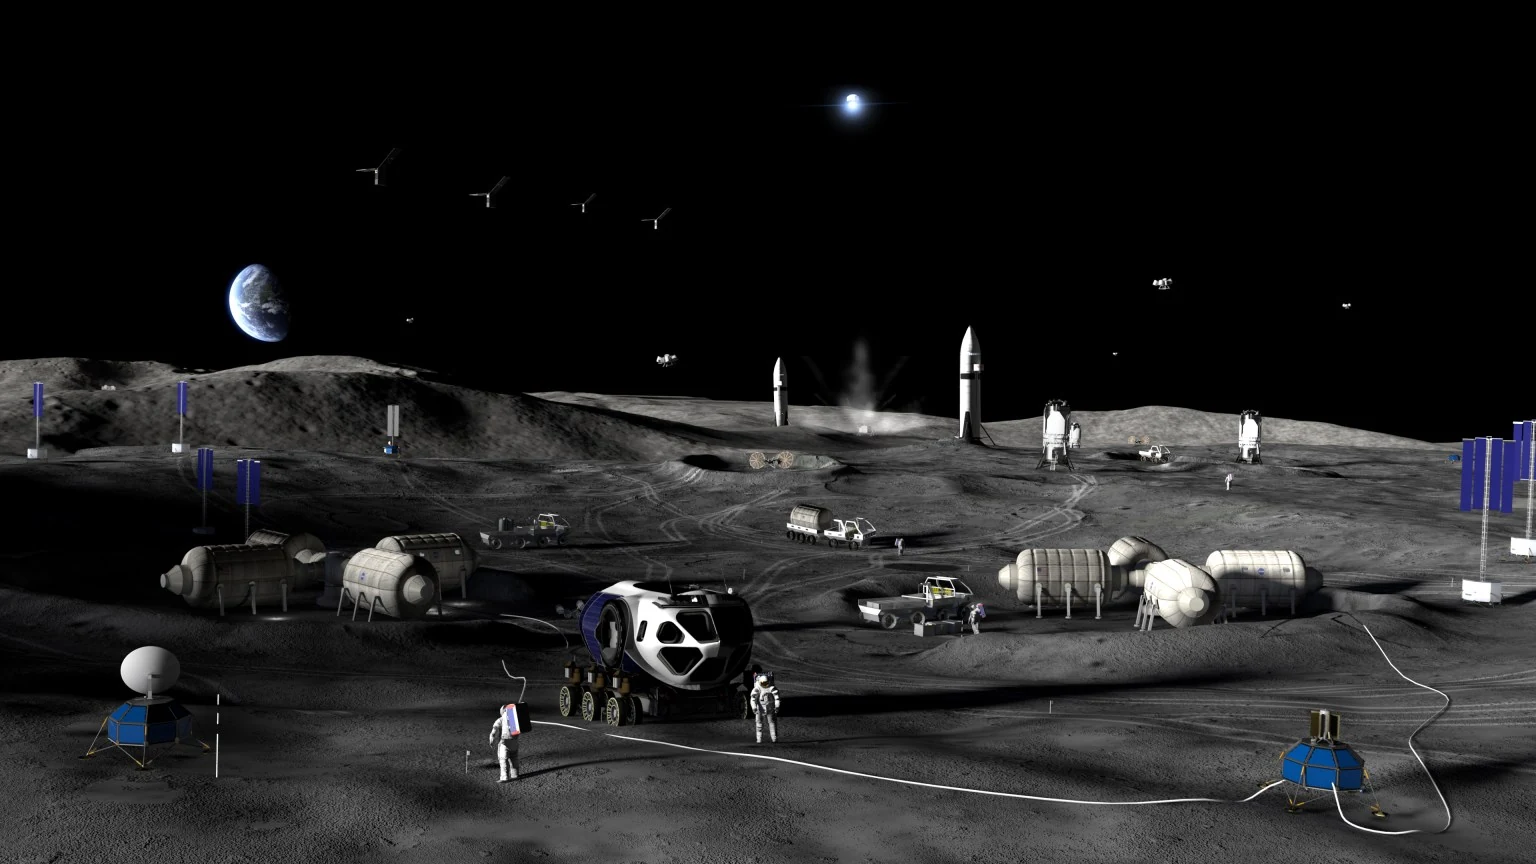
NASA’s Moon Base plans and commercial landers are opening a new chapter of lunar exploration.
FARFIELD Robotics is developing the ground crew: robots that put instruments, tools and intelligence where missions need them.
02 MISSION ROLES
Map routes, hazards and approaches to sites of interest.
Crater access. Ground-truth orbital resource maps for ISRU.
Carry instruments, equipment and tools. Free astronauts for the mission.
Revisit surface assets. Track damage, dust buildup and change.
03 DEVELOPMENT FOCUS
Our simulation stack combines reinforcement learning, route planning and recovery. Intelligence built around the mission.
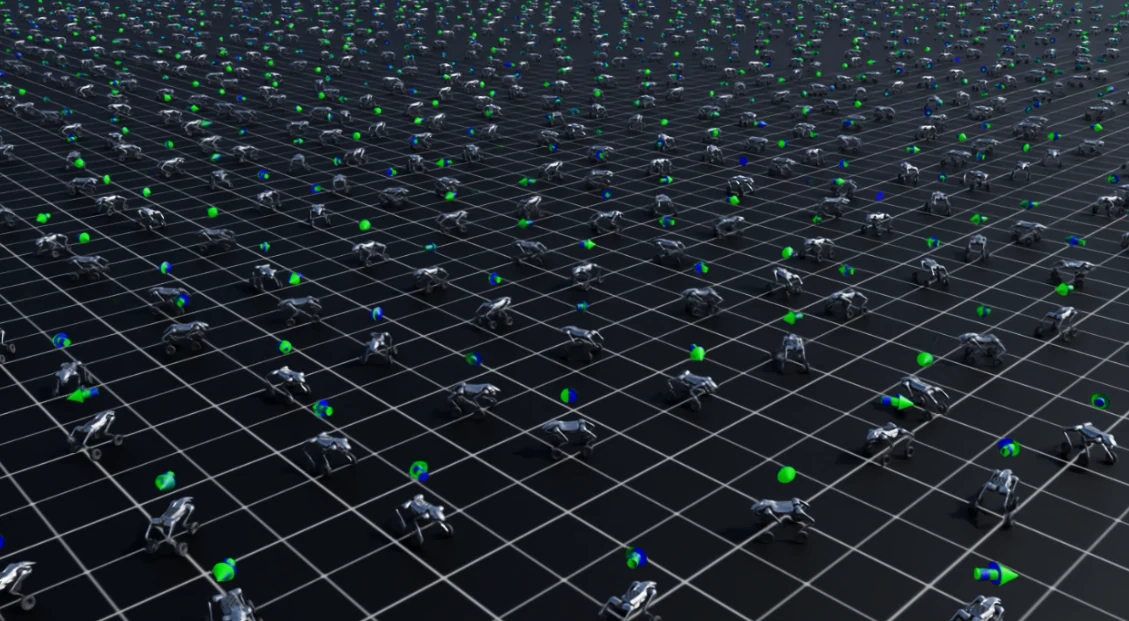
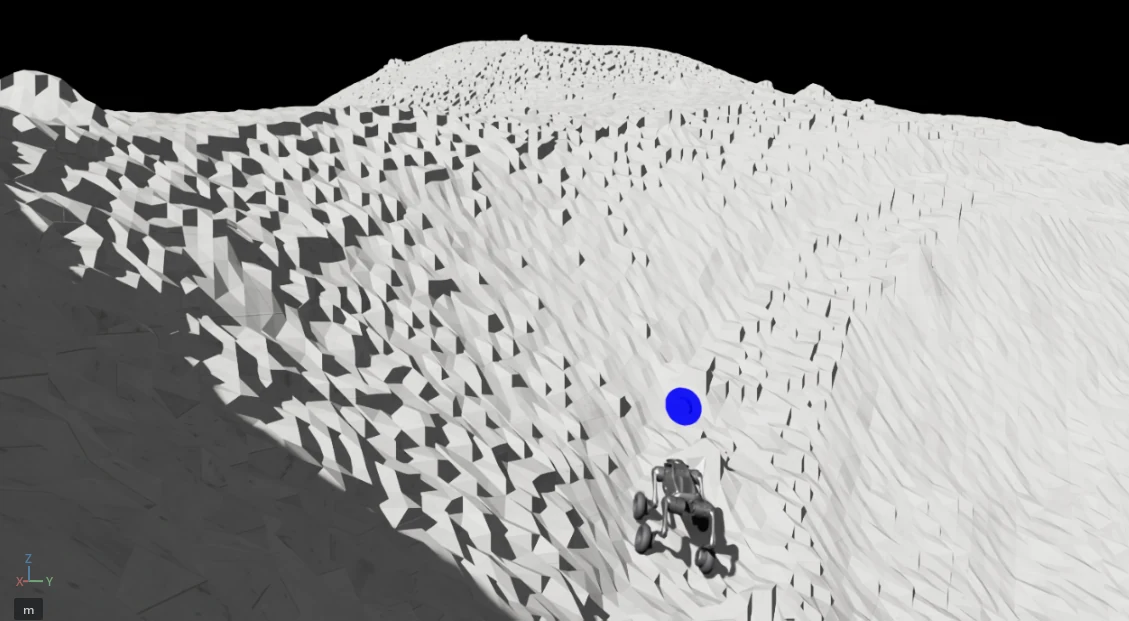
Physical AI for space. Starting with REXMI; extending over time to quadrupeds, humanoids and hybrids.